End Effectors, Force, Compliance & Contact
Designing grippers around the part: a friction-grip force estimate, positive capture and vacuum, passive versus active compliance, managing the transition into contact, and why collaborative safety belongs to the whole application, not the arm.
- 3 min
- 4 steps
- 3 questions
- Lesson 58 of 78
In this lesson
- Grip-force estimate
- Compliance as a design variable
- Contact modes
- Collaboration is system-specific
Picking up where you left off.
The end effector is where robot capability meets product uncertainty. Design it around object geometry, surface, fragility, contamination, tolerance, approach, release, verification, failure behavior, and service.
Grip-force estimate
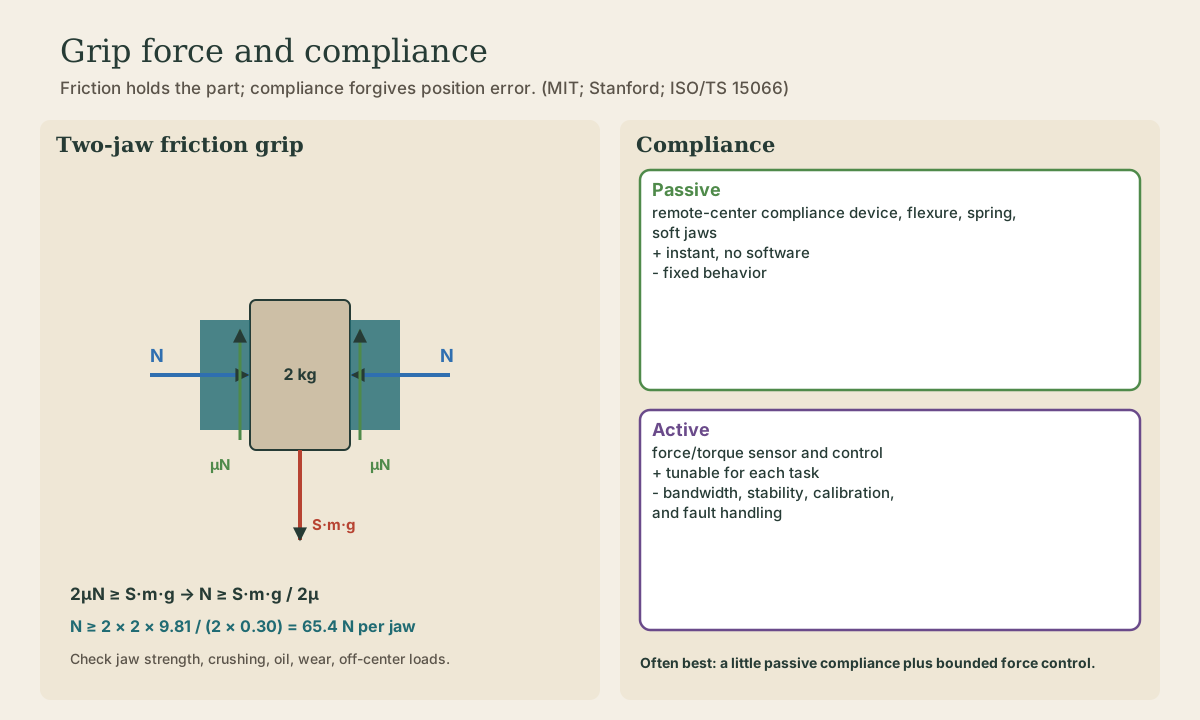
For a two-jaw friction grip lifting mass \(m\) vertically, a simple per-jaw normal force estimate is
where \(\mu\) is justified minimum friction and \(S\) covers acceleration and uncertainty. For 2 kg, \(\mu=0.30\), and \(S=2\), \(N\ge65.4\) N per jaw. Check jaw structure, actuator force at pressure or current extremes, part crushing, oil, wear, and off-center load.
Positive capture is preferable when loss would be severe. Vacuum systems need cup compliance, leakage tolerance, vacuum monitoring near the cup, reservoir/valve behavior, and a plan for porous or warped parts.
Quick check
N ≥ S·m·g / (2μ) = 2 × 2 × 9.81 / 0.6 ≈ 65.4 N per jaw.
Compliance as a design variable
Passive compliance—flexure, remote-center device, spring, soft jaw—responds quickly without software but has fixed behavior. Active compliance uses force/torque sensing and control for tunability but adds bandwidth, stability, calibration, and fault questions. Often a small amount of well-oriented passive compliance plus bounded force control works better than demanding perfect positioning.
Contact modes
Position control is appropriate in free space. Force or impedance behavior matters after contact. Define transition detection, maximum approach speed, allowable force, search envelope, timeout, retract behavior, and sensor-fault response.
Collaboration is system-specific
ISO/TS 15066 supplements robot safety requirements for collaborative applications 1. A smooth robot arm can still carry a sharp tool, trap a hand against a fixture, or eject a part. Evaluate the complete application and each lifecycle mode.
Tool dossier
Design an end effector for one variable part family. Include grasp principle, force calculation, tolerance accommodation, part-present/grip verification, loss-of-energy behavior, quick-change interface, cable/hose management, wear parts, cleaning, and a safe acceptance test with inert surrogates.
Practice
Mechanical or controlled compliance can make contact tasks tolerant and reduce peak force.
Practice
Safety is an application property involving robot, tool, payload, process, environment, modes, and people.
Lesson complete
Nice work.
Sources for this lesson
- 1ISO/TS 15066:2016 - Collaborative Robots. International Organization for Standardization. 2016. verifiedCurrent technical specification supplementing industrial-robot safety requirements for collaborative applications and work environments. Cited at: scope.
Further reading
- Introduction to Robotics. MIT OpenCourseWare. verifiedMechanisms, kinematics, planning, dynamics, controls, actuators, sensors, networks, interfaces, embedded software, laboratories, and a team robot project.
- CS223A / ME320 - Introduction to Robotics. Stanford University. verifiedCurrent physics-based syllabus covering spatial transformations, kinematics, Jacobians, dynamics, motion and force control, and vision-based control.
- Collaborative Robotics. Stanford University. verifiedProject-based course on task objectives, perception, control, teammate modeling, communication, consensus, and human-robot collaboration.